Low-Cost Swarm Robot Testbed for Ensemble Control
Overview
Our lab develops ensemble control algorithms that treat a swarm not as individual robots but as a distribution of poses. Using MPC / reinforcement learning, every robot receives the same linear and angular velocity command, yet the swarm as a whole can be steered through a range of pattern-formation tasks.
To validate these algorithms on real hardware we needed a swarm platform — but commercial robots are expensive and larger than necessary, which leads to collisions in a shared arena. Many labs face the same gap when they first start testing swarm algorithms. My task was to build a small, cheap, easy-to-replicate robot and the full testbed around it, so that other groups can reproduce it from open-source designs.
What I built
The robot
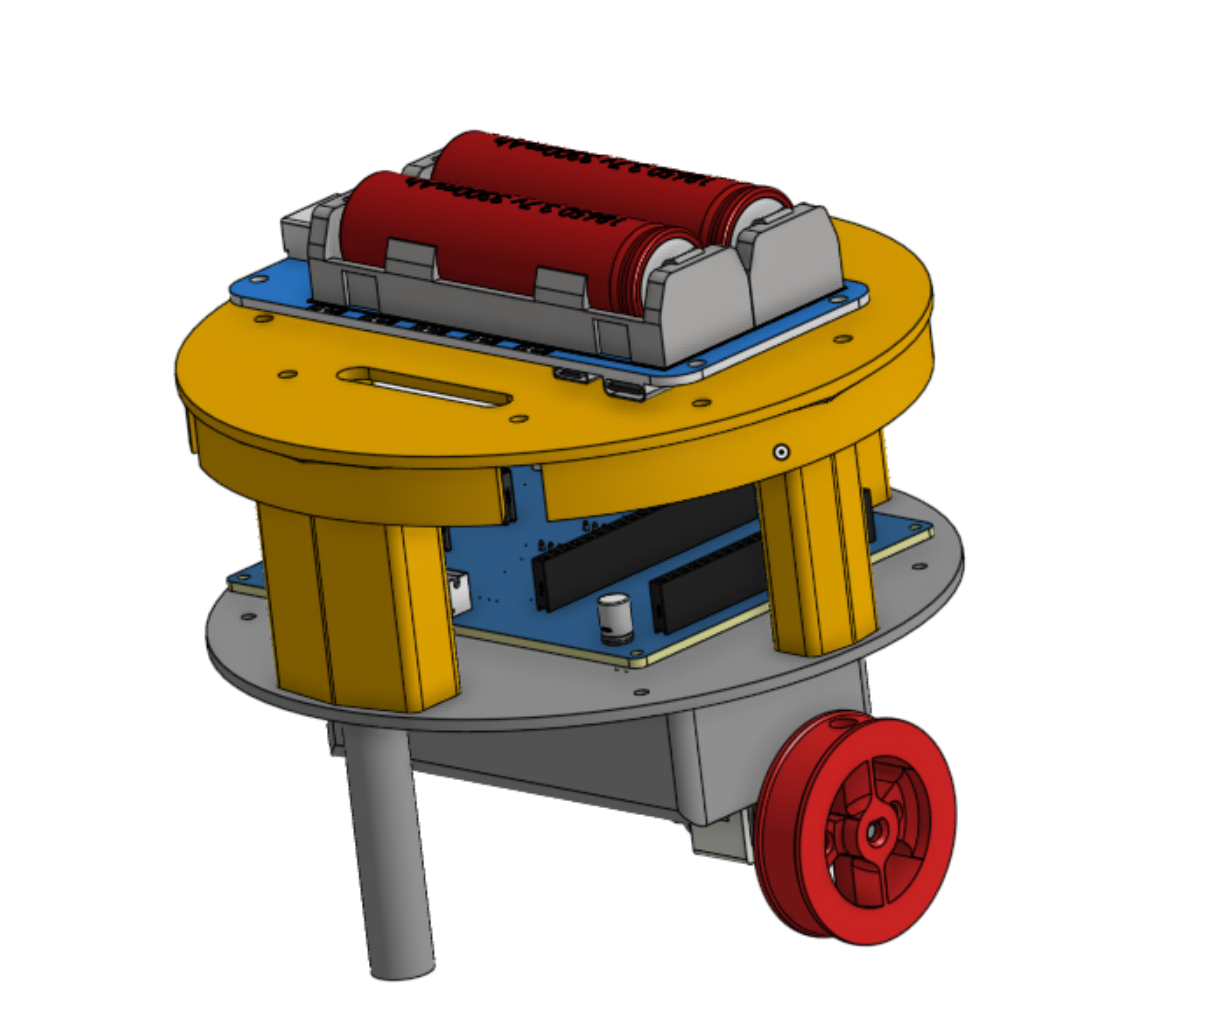
- Mechanical: designed a compact two-wheel differential-drive chassis and 3D-printed it.
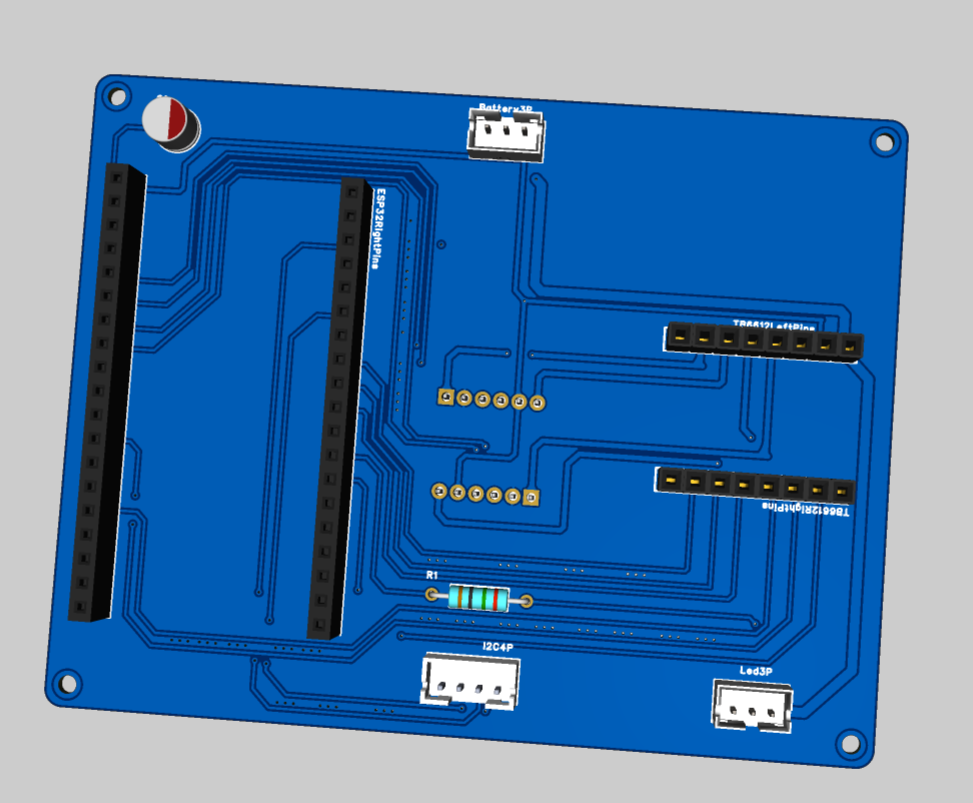
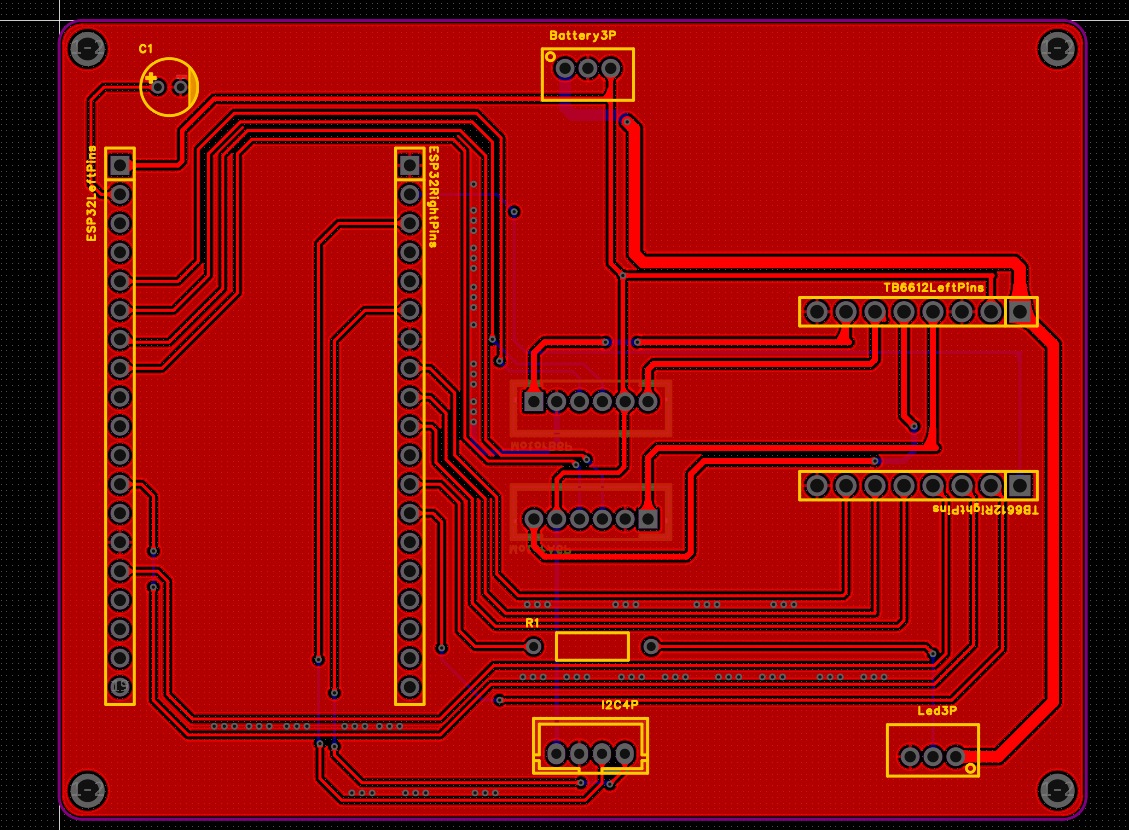
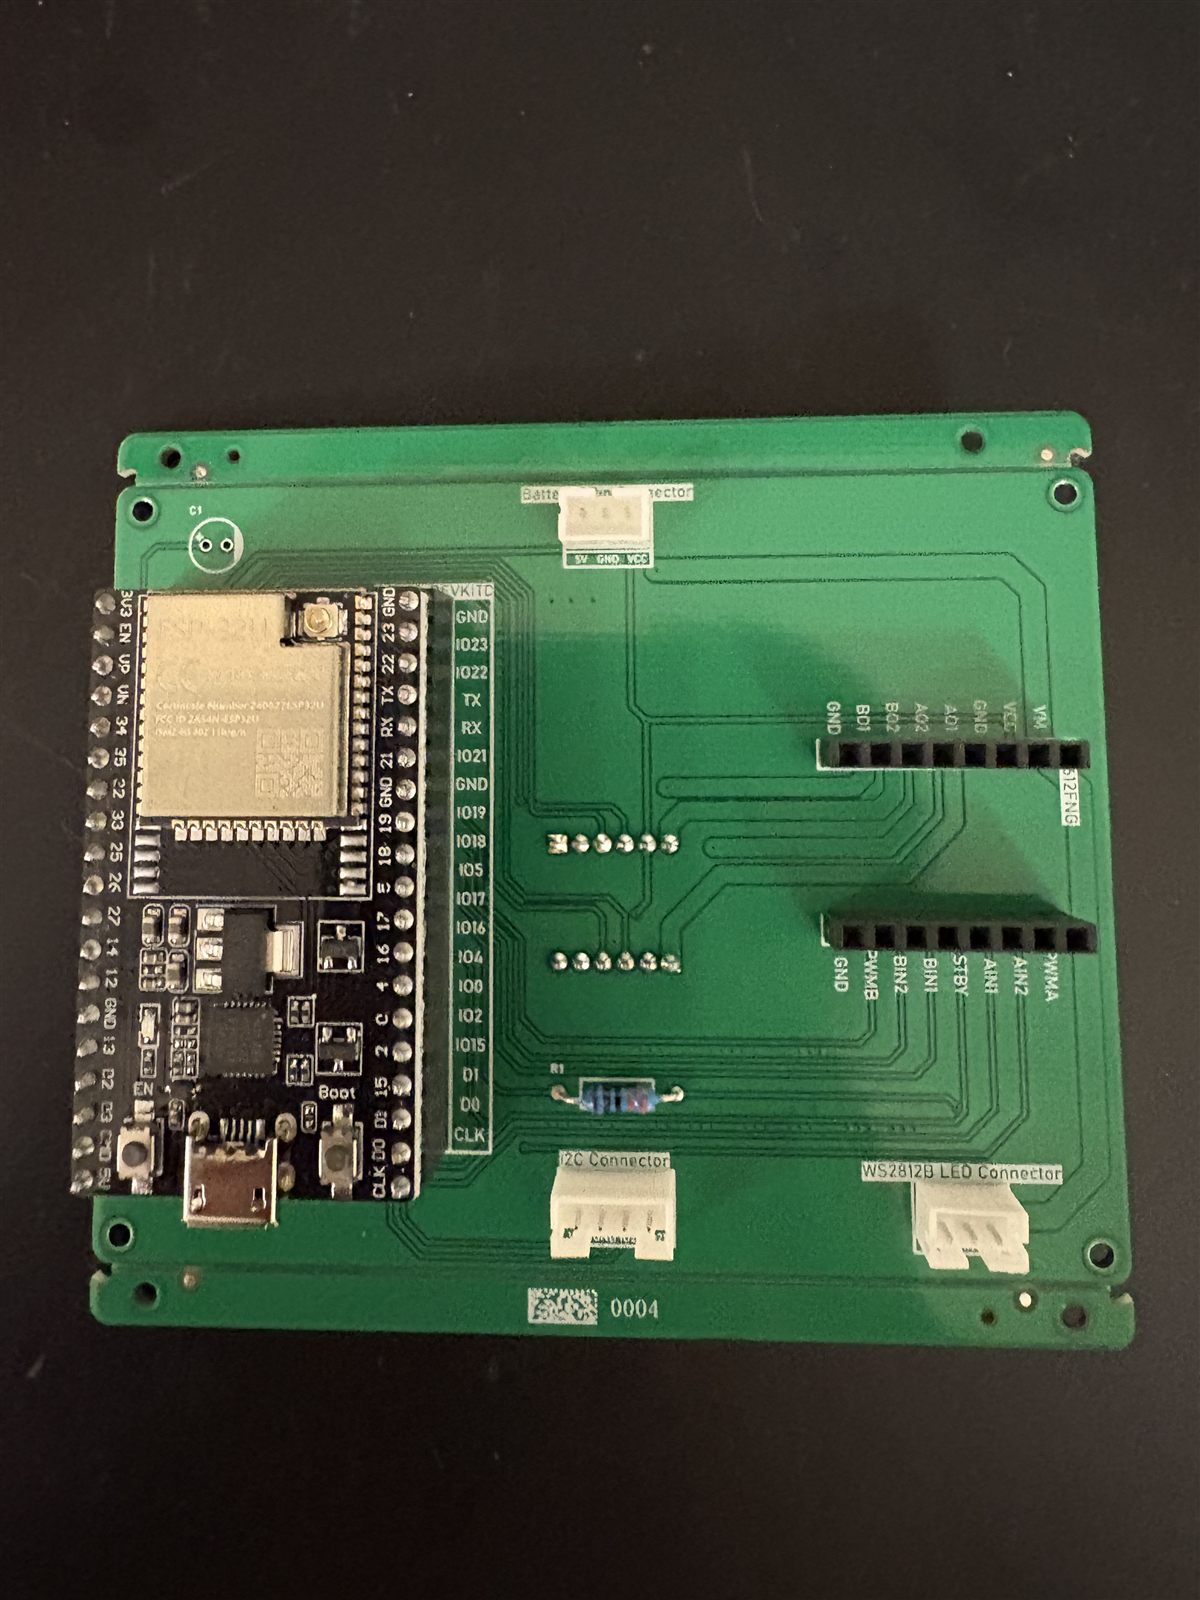
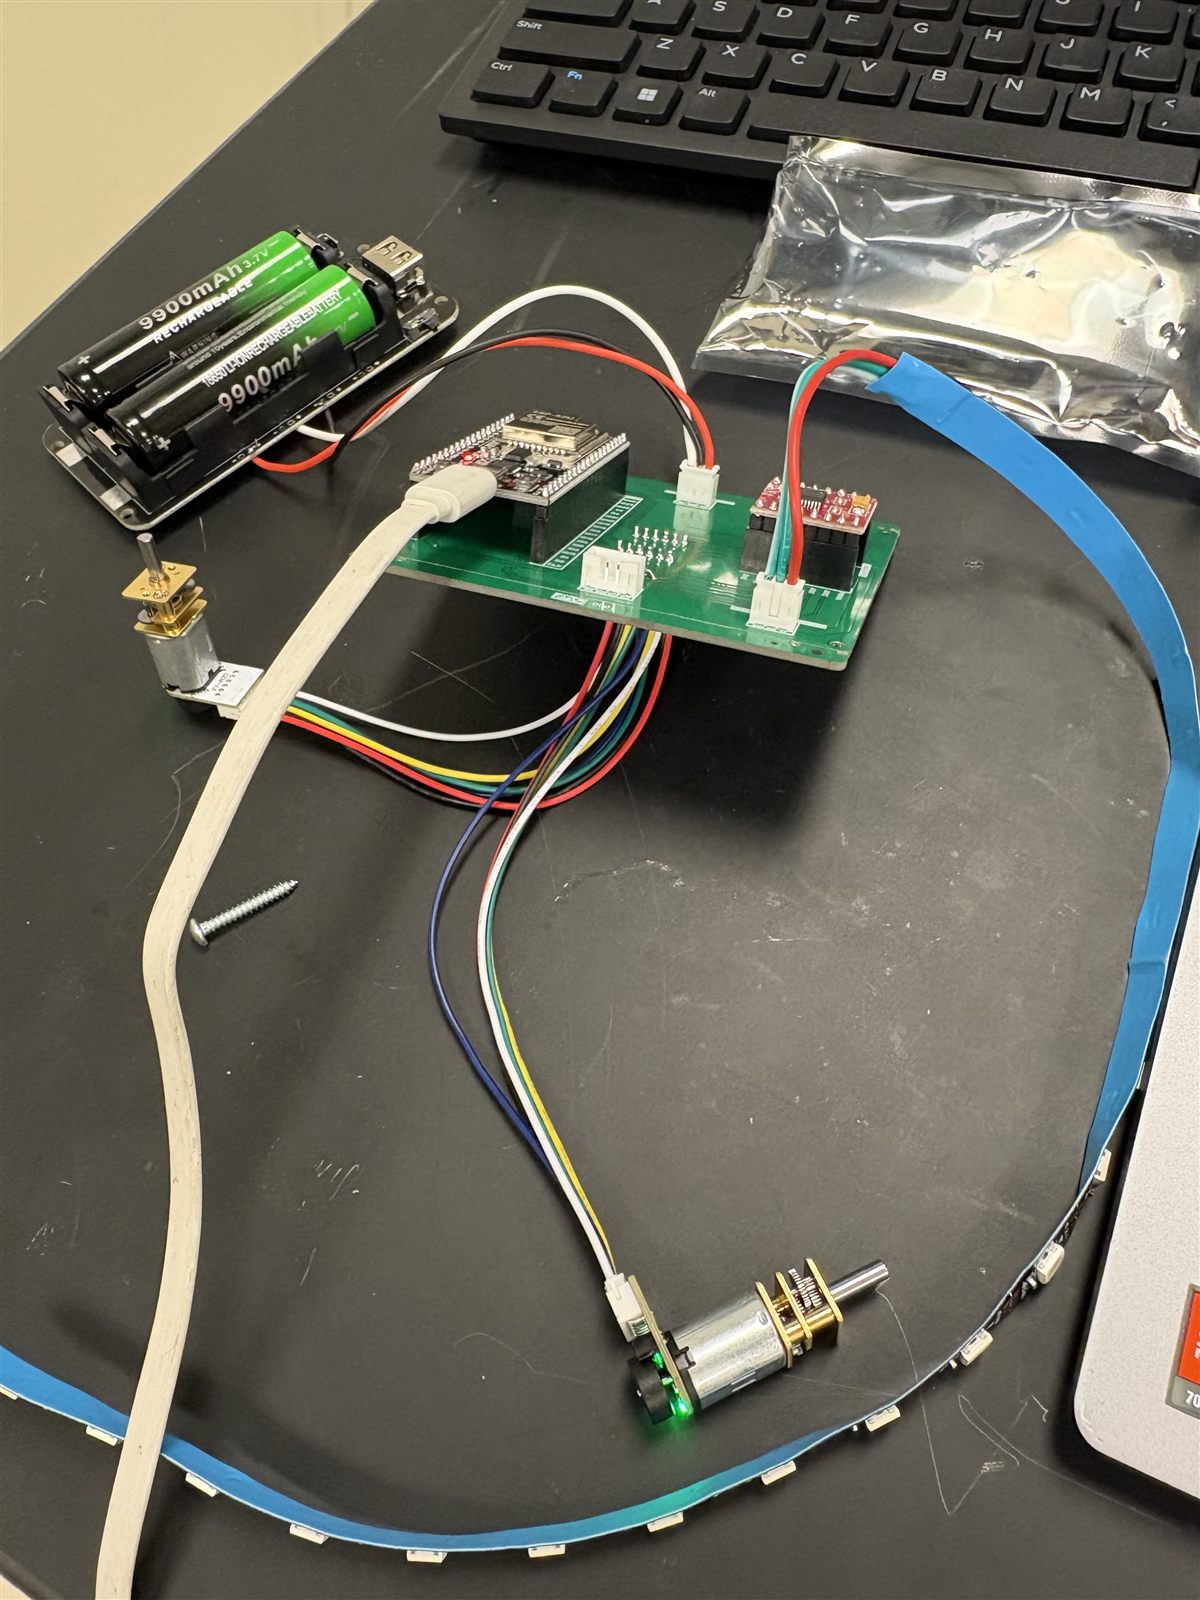
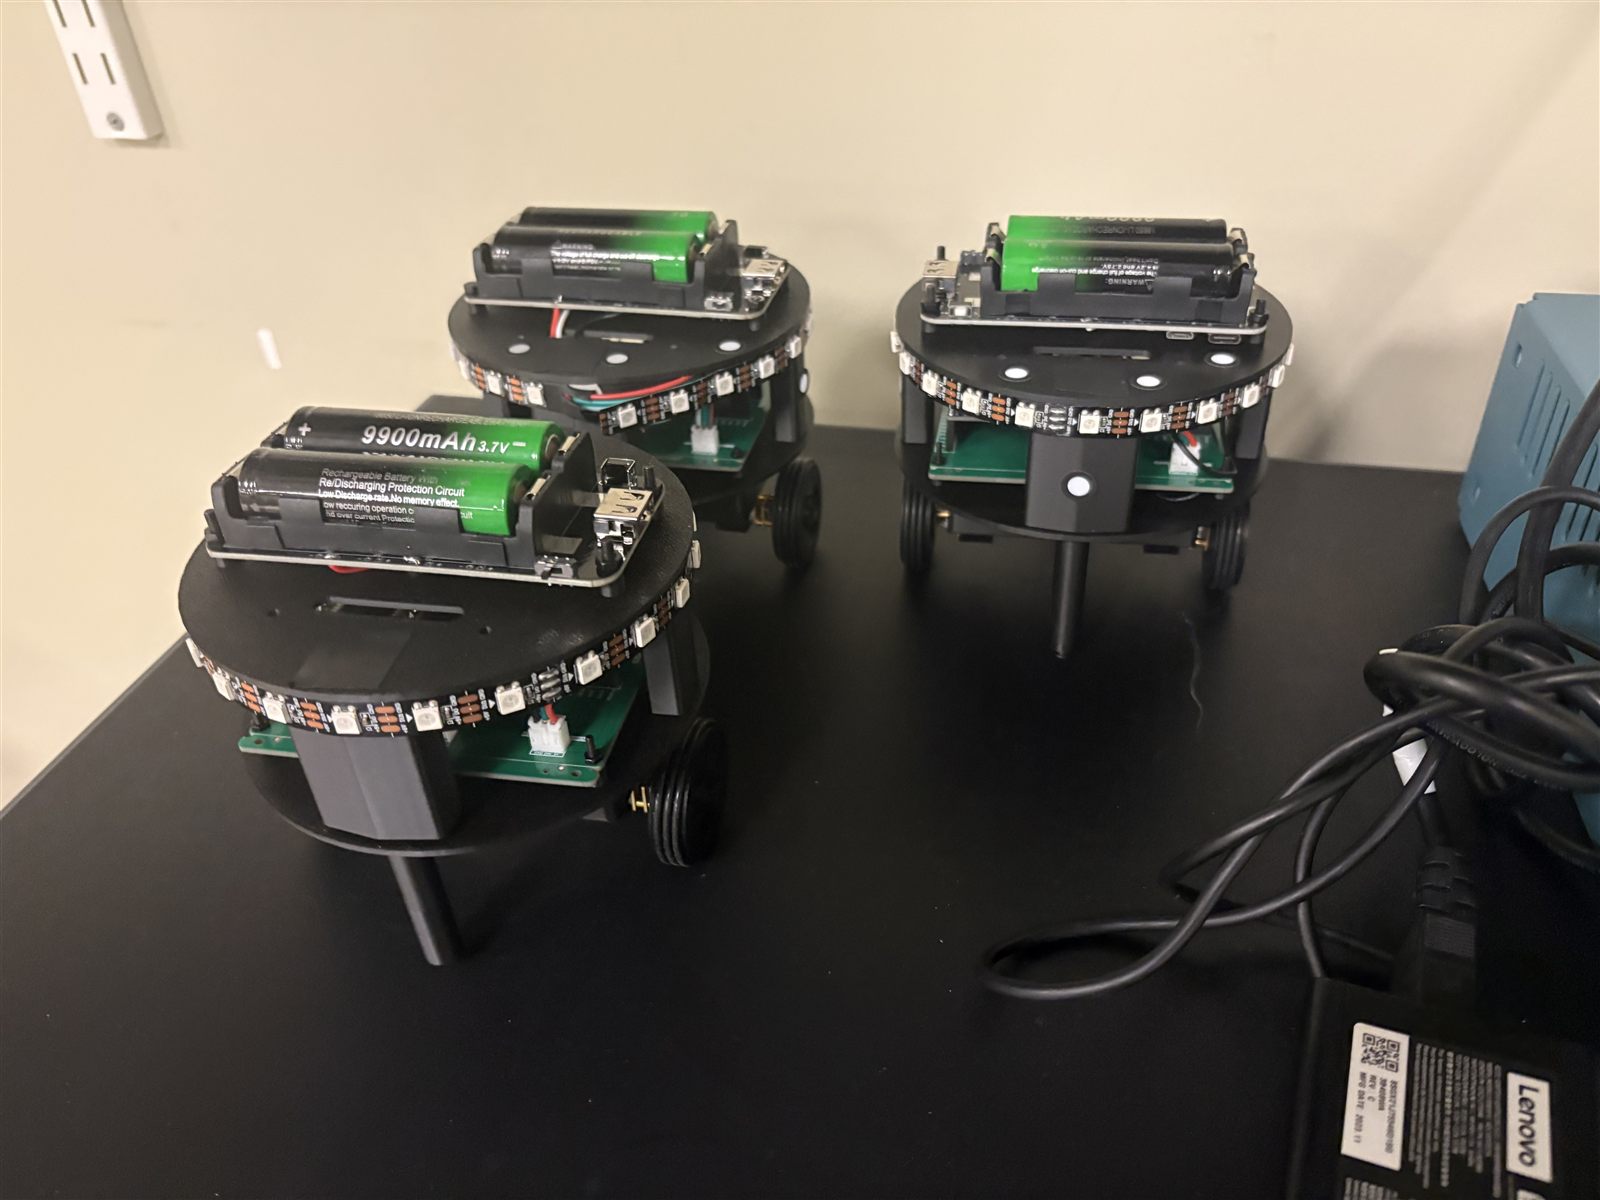
- Electronics: hand-wiring an ESP32, motor driver, LEDs and battery for every robot was slow and error-prone, so I taught myself EDA and designed a carrier PCB in LCEDA. The ESP32 and a TB6612FNG motor driver plug into headers, and the battery, WS2812B LED ring and I²C peripherals connect through JST connectors — assembly is now just plugging modules in.
- Firmware: wrote the ESP32 firmware that receives velocity commands over micro-ROS and drives the motors.
The testbed pipeline
- OptiTrackmotion capture tracks every robot
- ROS 2open-source modules publish each robot's pose
- Ensemble controllercomputes linear & angular velocity
- micro-ROSsends commands to each robot's IP over Wi-Fi
- ESP32 robotsexecute the motion
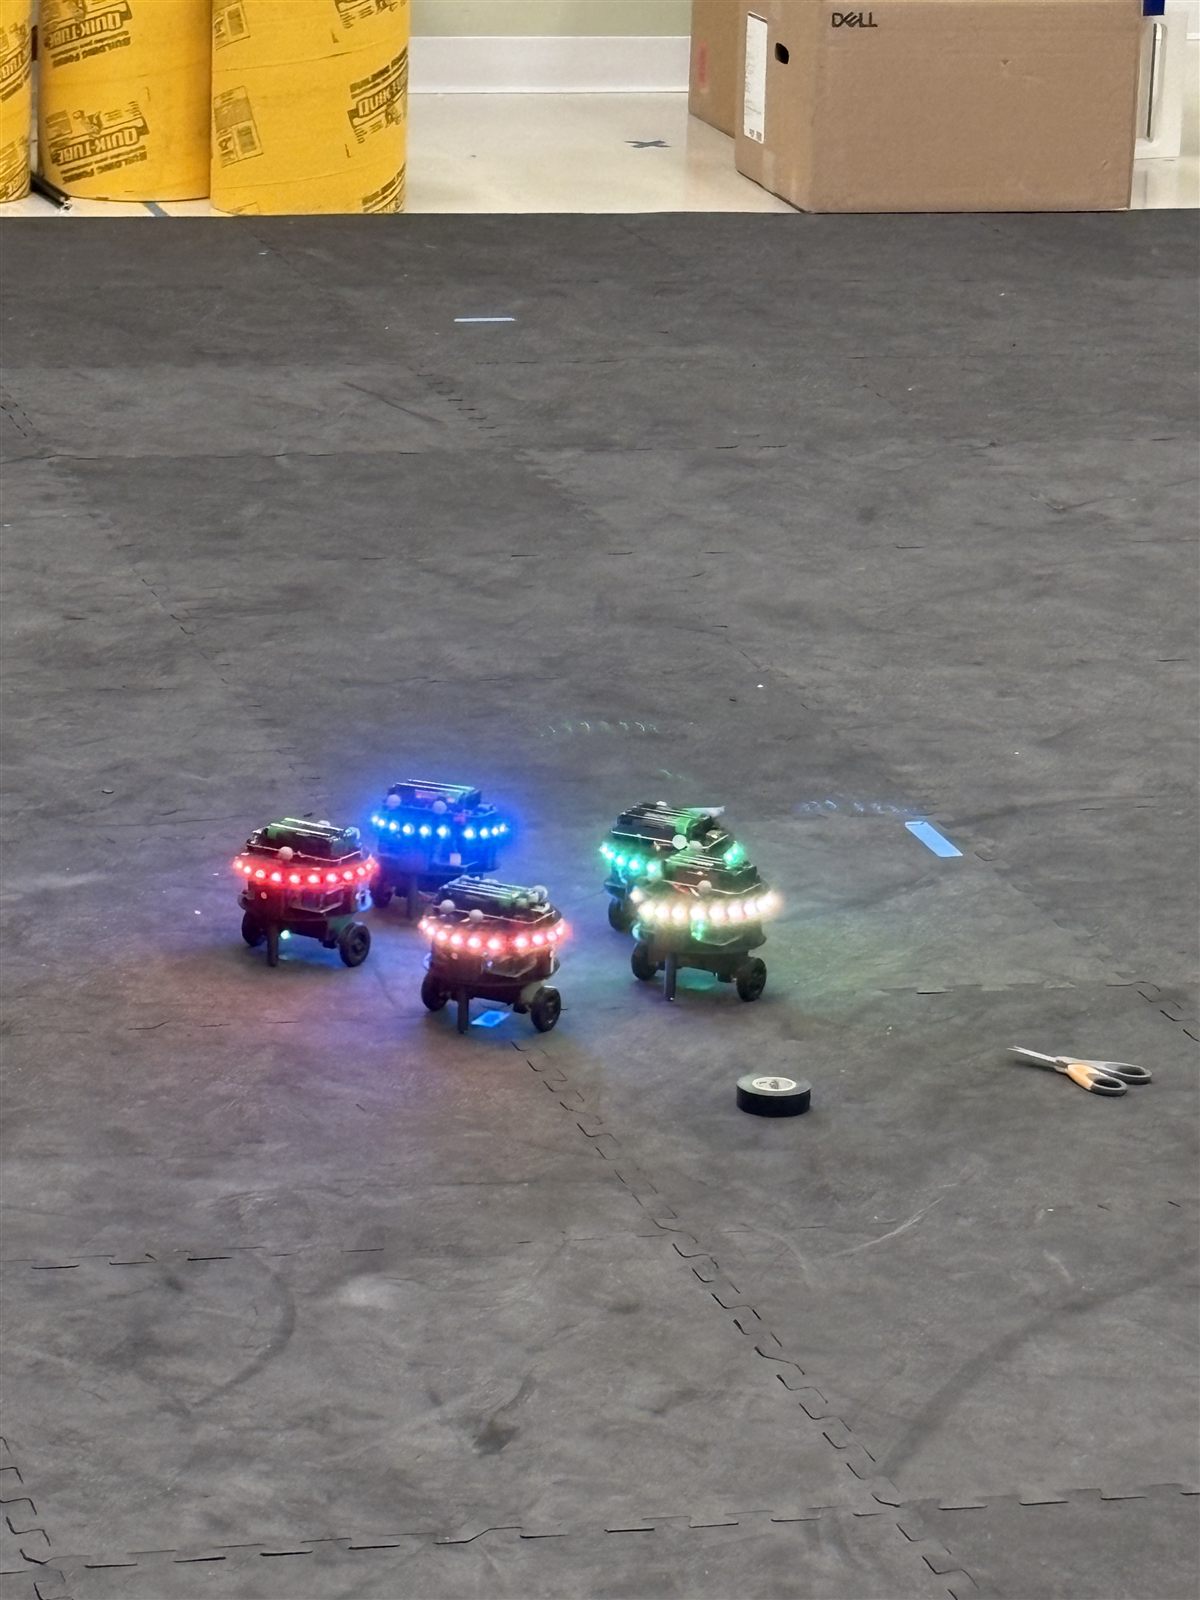
I built five robots and was responsible for all of the hardware testing.
Experiments
To make the tests harder, we split the floor into two regions with different resistance: when a robot crosses into the second region, its motor output is attenuated by a fixed percentage. The controller still has to steer the whole swarm with a single shared command.
Results
- Five robots running the ensemble controller end-to-end on real hardware.
- Paper submitted to ICRA 2027 (under review); I recorded the two hardware experiment videos included in the submission.
Open-source design files